HouseCat6D: A Large-Scale Multi-Modal Category Level 6D Object Perception Dataset with Household Objects in Realistic Scenarios
HyunJun Jung Shun-Cheng Wu Patrick Ruhkamp Guangyao Zhai Hannah Schieber Giulia Rizzoli Pengyuan Wang Hongcheng Zhao Lorenzo Garattoni Sven Meier Daniel Roth Nassir Navab Benjamin Busam
Technical University of Munich Toyota Motor Europe
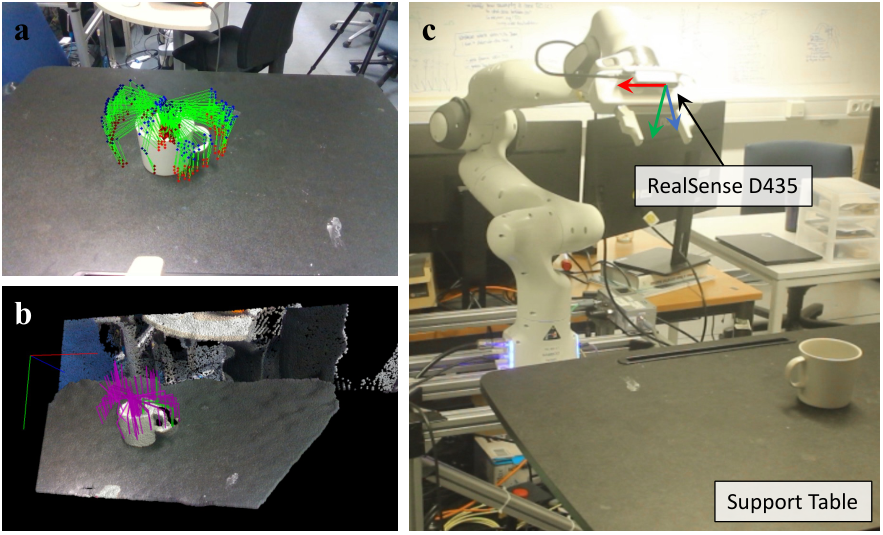
HouseCat6D is a category-level 6D object perception dataset with multi-modal RGB, depth, and polarimetric (RGBD+P) captures. It covers 194 diverse household objects across 10 categories, including photometrically challenging materials, with high-quality pose annotations, large-scale scenes, and dense robotic grasp labels. We also report benchmarks for leading category-level pose estimation methods.
Paper
@inproceedings{jung2024housecat6d,
  title={HouseCat6D - A Large-Scale Multi-Modal Category Level 6D Object Perception Dataset with Household Objects in Realistic Scenarios},
  author={Jung, HyunJun and Wu, Shun-Cheng and Ruhkamp, Patrick and Zhai, Guangyao and Schieber, Hannah and Rizzoli, Giulia and Wang, Pengyuan and Zhao, Hongcheng and Garattoni, Lorenzo and Meier, Sven and Roth, Daniel and Navab, Nassir and Busam, Benjamin},
  booktitle={Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR)},
  pages={22498--22508},
  year={2024}
}
Code
Dataset tools are available at Junggy/HouseCat6D.